Truman102208About UsNo. 1-436, Courtyard 8, Wenhua East Road, Changping District, Beijing, ChinaTruman is a well-known brand in the Chinese machinery industry, with main products including truss robots, robotic arms, seventh axis robots, and gantry robots. It can be used for coil material handling, automatic loading systems, intelligent unmanned overhead crane systems, factory three-dimensional warehouse construction, warehouse location management systems, etc. It has strong research and development capabilities, mature technology, and serves dozens of well-known enterprises, providing automated handling solutions for domestic and foreign manufacturing enterprises, logistics enterprises, etc.Truman102208About UsNo. 1-436, Courtyard 8, Wenhua East Road, Changping District, Beijing, ChinaTruman is a well-known brand in the Chinese machinery industry, with main products including truss robots, robotic arms, seventh axis robots, and gantry robots. It can be used for coil material handling, automatic loading systems, intelligent unmanned overhead crane systems, factory three-dimensional warehouse construction, warehouse location management systems, etc. It has strong research and development capabilities, mature technology, and serves dozens of well-known enterprises, providing automated handling solutions for domestic and foreign manufacturing enterprises, logistics enterprises, etc.TrumanTrumanTrumanTrumanTrumanTrumanTrumanTrumanT
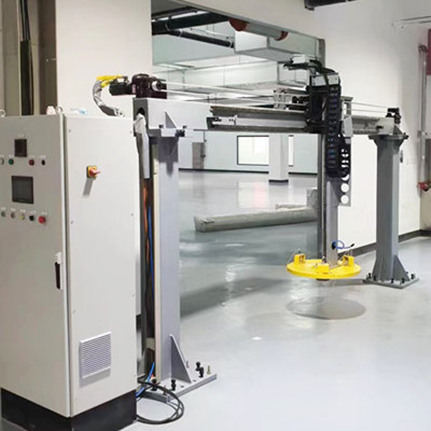
The mechanical arm for adding and removing the lid of the material bucket can automatically grab the lid of the material bucket and move it to the designated position for stacking. The main structure of the overall equipment is welded with Q235A steel. The two axis handling truss manipulator consists of X axis, Z axis, gripper, and column. The X/Z axis is driven by a servo motor to drive a planetary reducer, synchronous belt, and gear rack transmission. The gripper is composed of suction cups and cover mechanisms, meeting the customer's load, speed, and accuracy requirements, and achieving high-speed and efficient operation. Project requirements: Box lid stacking method: 20 layers Dimensions after palletizing: 1078X1078X1205mm (including cover) Weight of box cover after palletizing: ≤ 1000kg Homework process: The WMS system issues empty bucket supply tasks in advance based on feeding instructions from the central control system, and the WCS system triggers handling instructions; The robot scheduling system RCS schedules AGV to transport empty buckets to the empty bucket buffer position and to the adding and removing cover station. The adding and removing cover truss robotic arm completes the removal of the cover, and AGV transports the empty buckets to the feeding station and puts them down. The task information is fed back to WCS; The quantitative feeding of the feeder is completed, WCS triggers the handling task, RCS dispatches AGV to the feeding station to transport the solid barrels to the adding and removing cover station, and the adding and removing cover truss manipulator completes the covering. AGV transports the solid barrels to the lifting chamber and puts them down. AGV exits the lifting machine to perform other tasks, feedback information to WCS, and the task is completed.
 English
 简体中文